Zizhuo Wang王子卓

Robotics & Embodied AI Researcher

I am currently a senior undergraduate student at Tsinghua University, working on robotics and embodied intelligence. I recently spent a wonderful summer at UC Berkeley's EMBER Center, advised by Prof. Shankar Sastry. I have also been fortunate to work closely with Prof. Yiming Li, Prof. Hang Zhao, and Prof. Shuguang Li.

I particularly enjoy bridging learning algorithms and real robotic systems, where physical interaction not only tests our ideas but also inspires new ones.

I am currently seeking PhD opportunities starting in Fall 2027, and I would be excited to connect and explore potential research opportunities and collaborations.

Research Interests

My research has spanned robot design, humanoid locomotion, tactile-informed robot learning, and manipulation. More recently, I have become particularly interested in agentic robot self-improvement.

My research interests include:

  1. Agentic Robotics & Self-Improvement
  2. Humanoid Robotics & Whole-Body Control
  3. Tactile Sensing & Contact-Rich Interaction
Beyond Research

Life always comes first! 😏

I can hardly imagine life without sports. I've played basketball 🏀 for eight years, and since coming to Tsinghua, I've also picked up tennis 🎾 and started working out 💪.

I love traveling and spending time in nature 🏞️. One of my biggest dreams is to travel around the world, explore its hidden corners, and discover all the wonders it has to offer 🤩.

Recently, I've also gotten into photography 📸. I'm still very much a beginner, but that's part of the fun—there's always something new to learn and capture! 🚀

Publications

* Equal contribution

TactileStep: Sole Tactile Learning for Regulating Foot–Terrain Interaction in Humanoid Locomotion

Zizhuo Wang (equal contribution), Ming-Ju Lee (equal contribution), Shaoting Zhu, Haozhe Lou, Hang Zhao, Yiming Li

CoRL 2026Spotlight (3.4%)

TactileStep integrates deployable sole-pressure feedback with phase-aware reinforcement learning to regulate foot–terrain contact, enabling softer landings and more stable support during humanoid locomotion.
Echo in the Steps: Learning Perceptive Humanoid Parkour with Gated Memory

Ming-Ju Lee (equal contribution), Zizhuo Wang (equal contribution), Shaoting Zhu, Haozhe Lou, Hang Zhao, Yiming Li

CoRL 2026

An end-to-end humanoid parkour framework combines foothold saliency, gated temporal memory, and alternating-step regularization to achieve precise foot placement on sparse terrain using onboard depth sensing.

Computational Design of Customized Tendon-Driven Origami End-Effectors for Enveloping Grasp

Zizhuo Wang, Peiwen Yang, Shuguang Li

RA-L 2026Under review

An end-to-end framework uses reinforcement learning to design object-specific origami grippers from target meshes, translating optimized geometries into manufacturable crease patterns and single-motor tendon-driven hardware for reliable, high-load enveloping grasps.

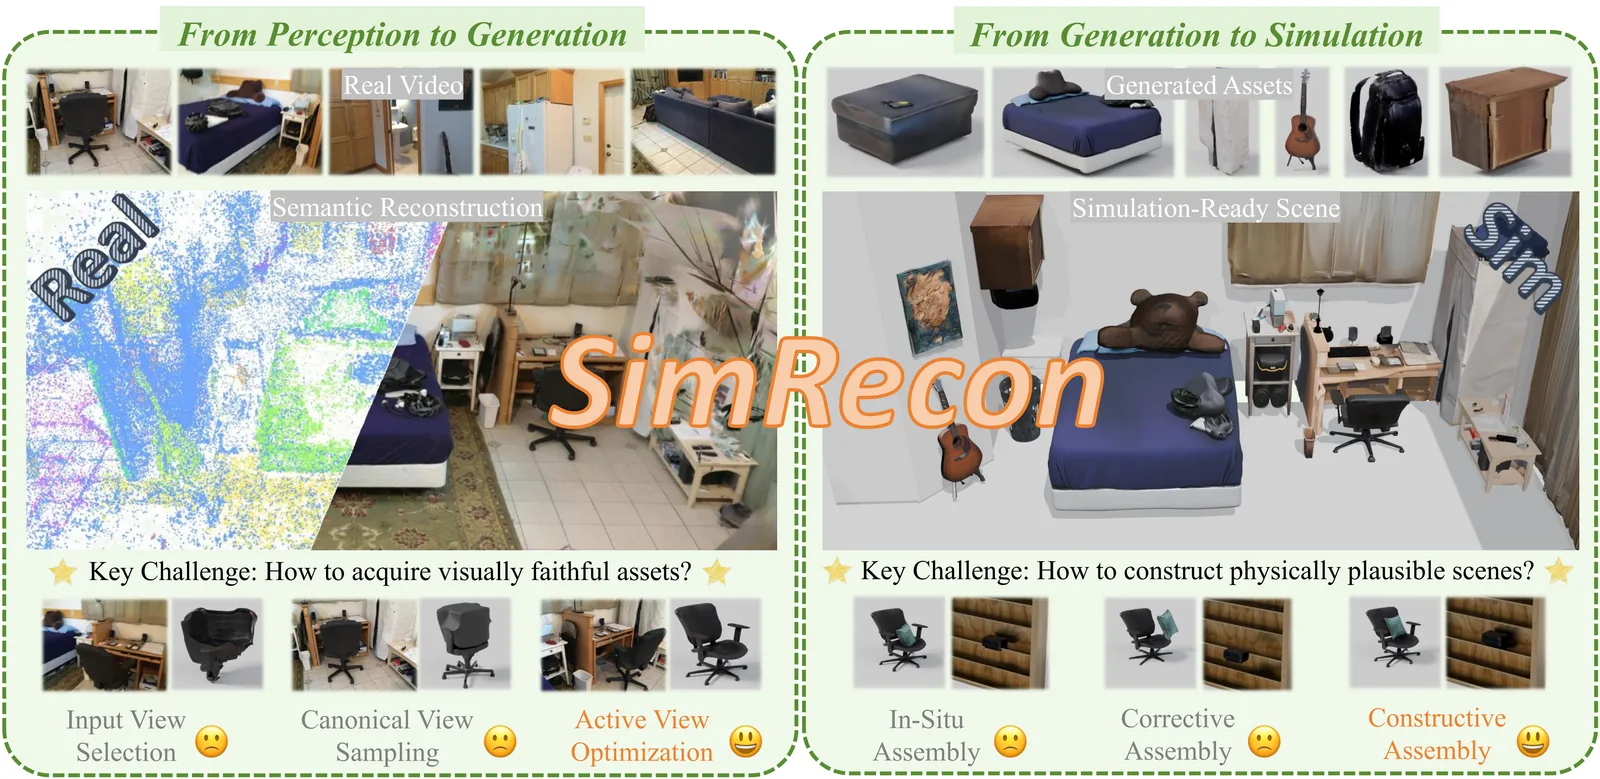
SimRecon pipeline for reconstructing simulation-ready object-centric scenes from real videos

SimRecon: SimReady Compositional Scene Reconstruction from Real Videos

Chong Xia (equal contribution), Kai Zhu (equal contribution), Zizhuo Wang, Fangfu Liu, Zhizheng Zhang, Yueqi Duan

CVPR 2026Highlight

SimRecon reconstructs object-centric, simulation-ready scenes from real videos through a Perception–Generation–Simulation pipeline designed for high visual fidelity and physical plausibility.

Research Experience

  1. THUSI Lab (Tsinghua Spatial Intelligence Lab)

    to Present

    College of AI, Tsinghua University

    Advisor: Prof. Yiming Li

    Research: Humanoid Robot Learning & Agentic Robot Self-Improvement

  2. EMBER Center (Embodied Intelligence & Robotics Center)

    to

    University of California, Berkeley

    Advisor: Prof. S. Shankar Sastry

    Research: Robot Manipulation

  3. IVG Lab

    to

    Department of Electronic Engineering, Tsinghua University

    Advisor: Prof. Yueqi Duan

    Research: Real-to-Sim Reconstruction

  4. The ShuGuang Lab (SGLab)

    to

    Department of Mechanical Engineering, Tsinghua University

    Advisor: Prof. Shuguang Li

    Research: Computational Design & Fabrication of Origami Robots